One shared program
Robot, world, behavior and checks stay connected by name.
RobotDSL is a family of languages for robot development. One program describes the robot, its world, its behavior and how it is evaluated; a compiler assembles the machine, derives its settings and checks the whole system before anything runs. MobileDSL, for mobile robots, is the first language of the family.
Robot, world, behavior and checks stay connected by name.
Check assembly and references before generating ROS and Gazebo files.
MobileCopilot finds parts, writes the program and uses compiler feedback.
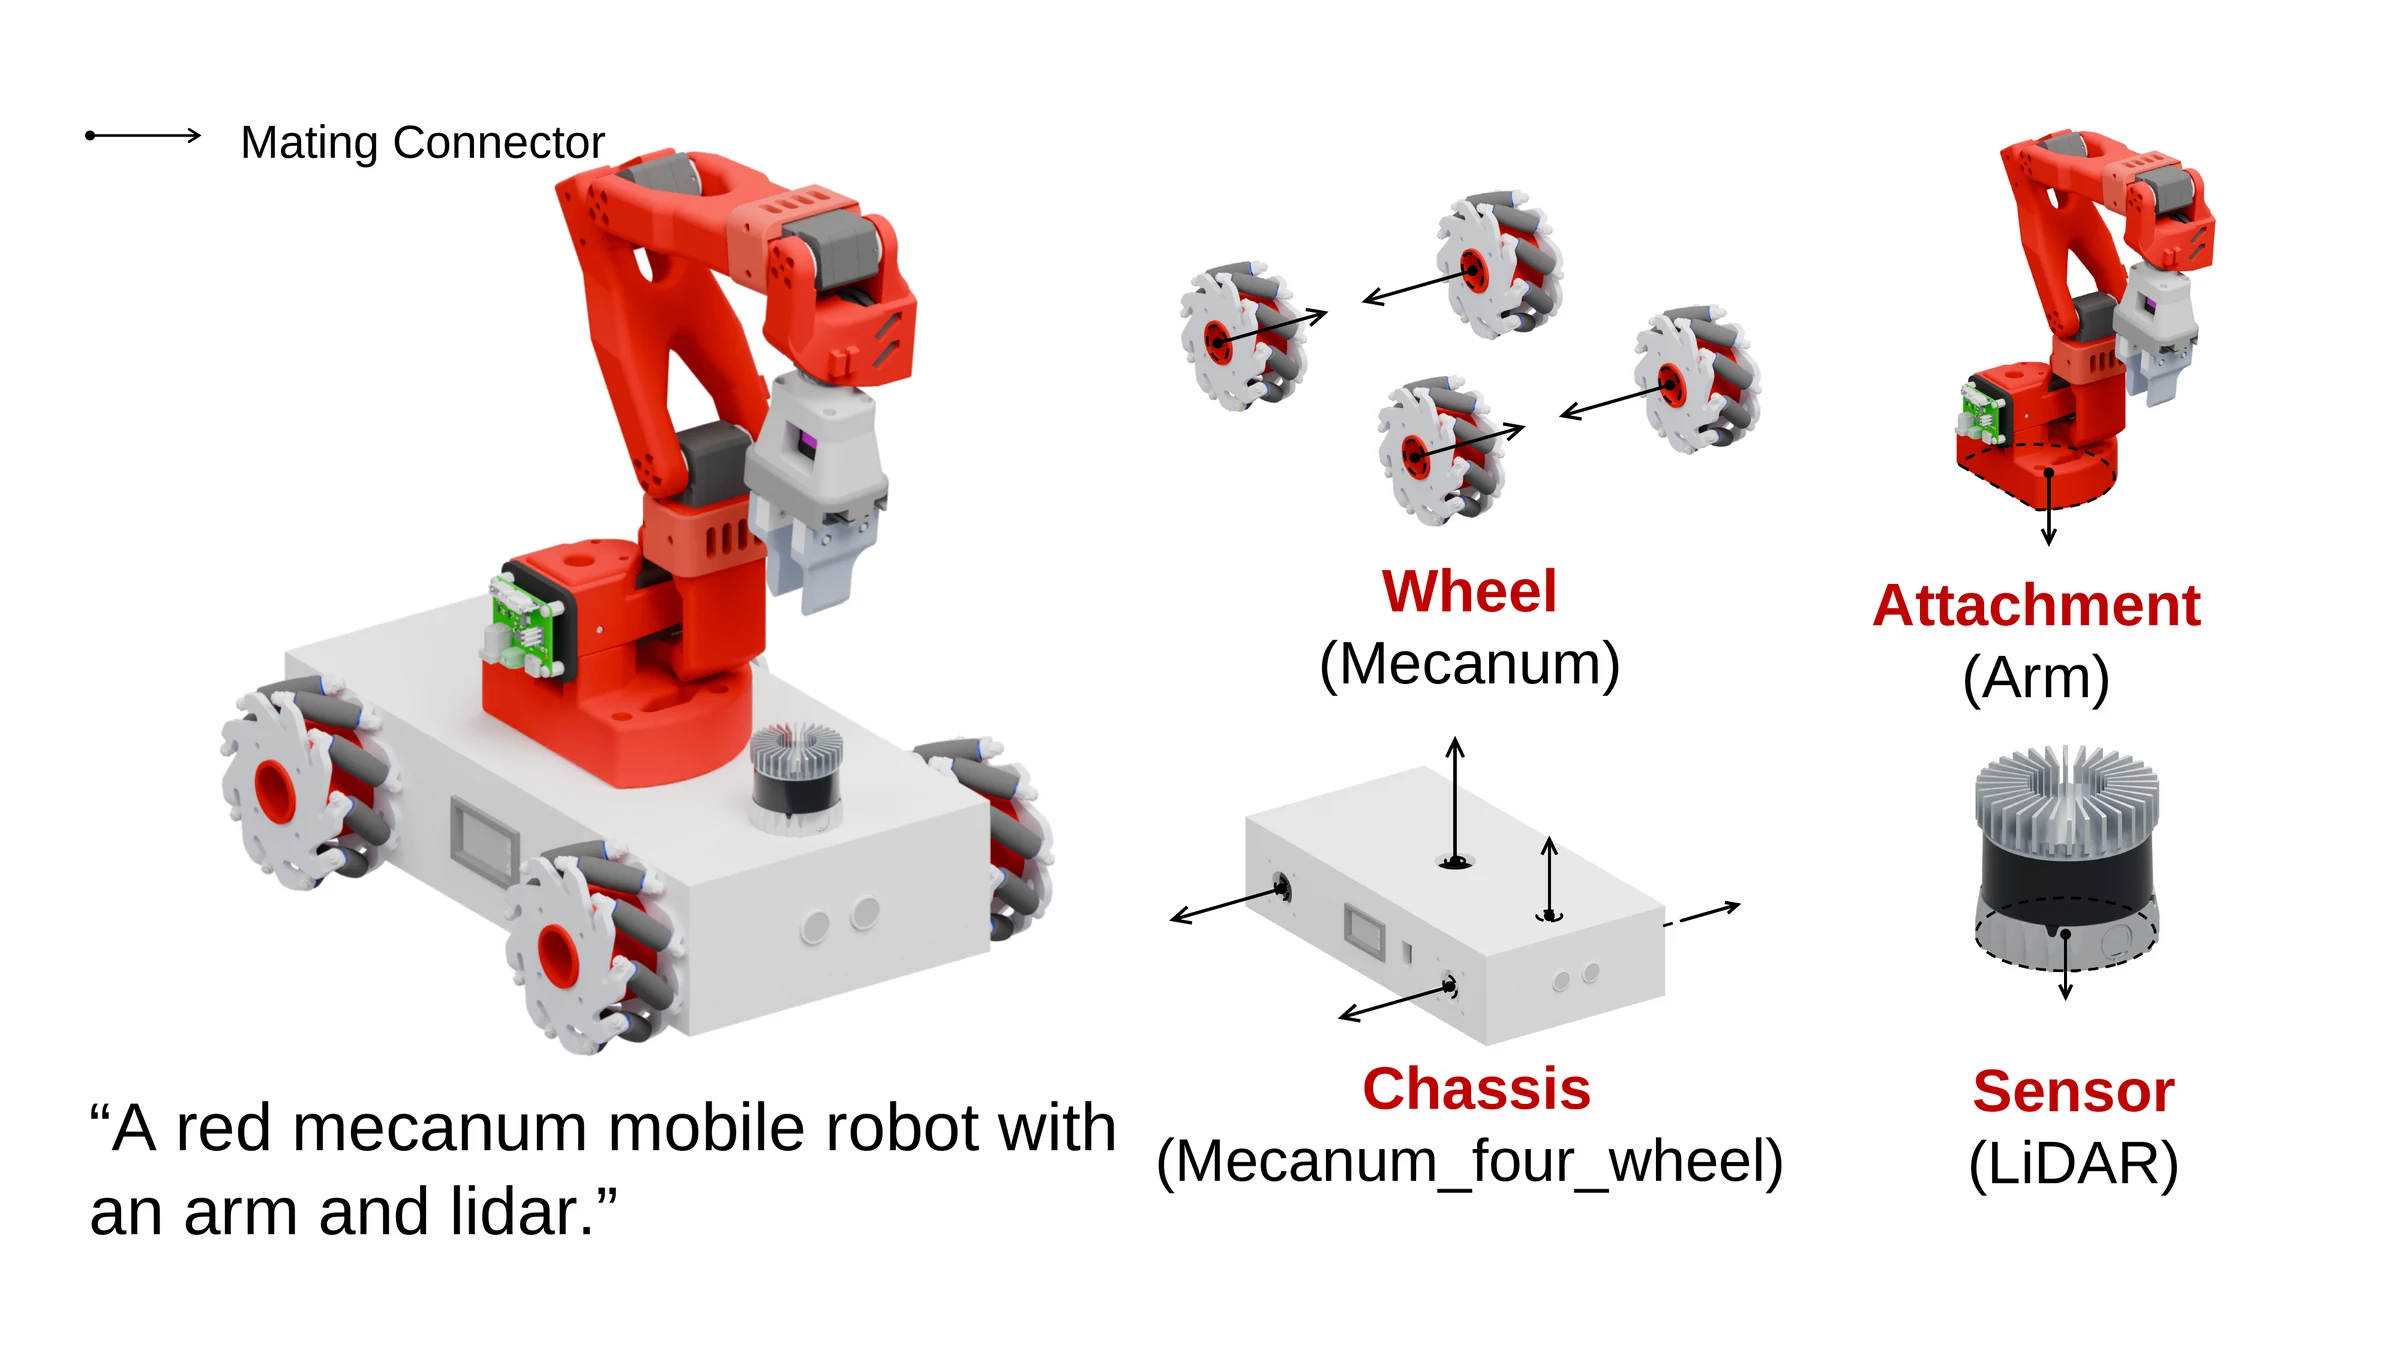
Robot nav_bot { intent "A mecanum robot with a lidar and an arm" Mecanum_four_wheel chassis(ref = "silver") Mecanum wheel_lf(ref = "red", glue = (0.0976, 0.095, -0.0443, 0, 1, 0)) Mecanum wheel_lb(ref = "red", glue = (-0.1124, 0.095, -0.0443, 0, 1, 0)) Mecanum wheel_rf(ref = "red", glue = (0.0976, -0.095, -0.0443, 0, -1, 0)) Mecanum wheel_rb(ref = "red", glue = (-0.1124, -0.095, -0.0443, 0, -1, 0)) Lidar front_scan(ref = "lidar", glue = (0.11, -0.0001, -0.0043, 0, 0, -1)) Attachment top_arm(ref = "arm", glue = (-0.0073, -0.0001, -0.0043, 0, 0, -1))}
Loading the 3D model…
Execution success in simulation
Time per design
API cost per design
Execution success in simulation, MobileDSL vs. ROS/Gazebo files: Codex / gpt-5.6-sol 74% vs. 24% · Codex / gpt-6-astra 82% vs. 40% · Claude Code / claude-opus-4-8 64% vs. 22%.
Time per design: 4.8 vs. 12.2 min · 2.5 vs. 4.2 min · 4.5 vs. 9.5 min.
API cost per design: $0.55 vs. $1.41 · $0.87 vs. $1.29 · $1.49 vs. $2.96.
Navigating around corridor obstacles, with onboard RGB and depth on the right.
Ask questions, share robot designs and follow announcements.
Browse the parts library and edit a design in the browser.
Upload a mesh and its connectors; after review it joins the shared library, credited to you.
Tell us when a generated design looks wrong or the site misbehaves.
@misc{robotdsl_mobilecopilot,
  title        = {MobileCopilot: A Domain-Specific Language Framework
                  for Agentic Mobile Robot Design},
  author       = {{RobotDSL Team}},
  howpublished = {\url{https://robotdsl.csail.mit.edu/}}
}